Wiki article · Collection 05
Digital Power
Engineering reference on Digital Power for wireless power system design, integration, and deployment.
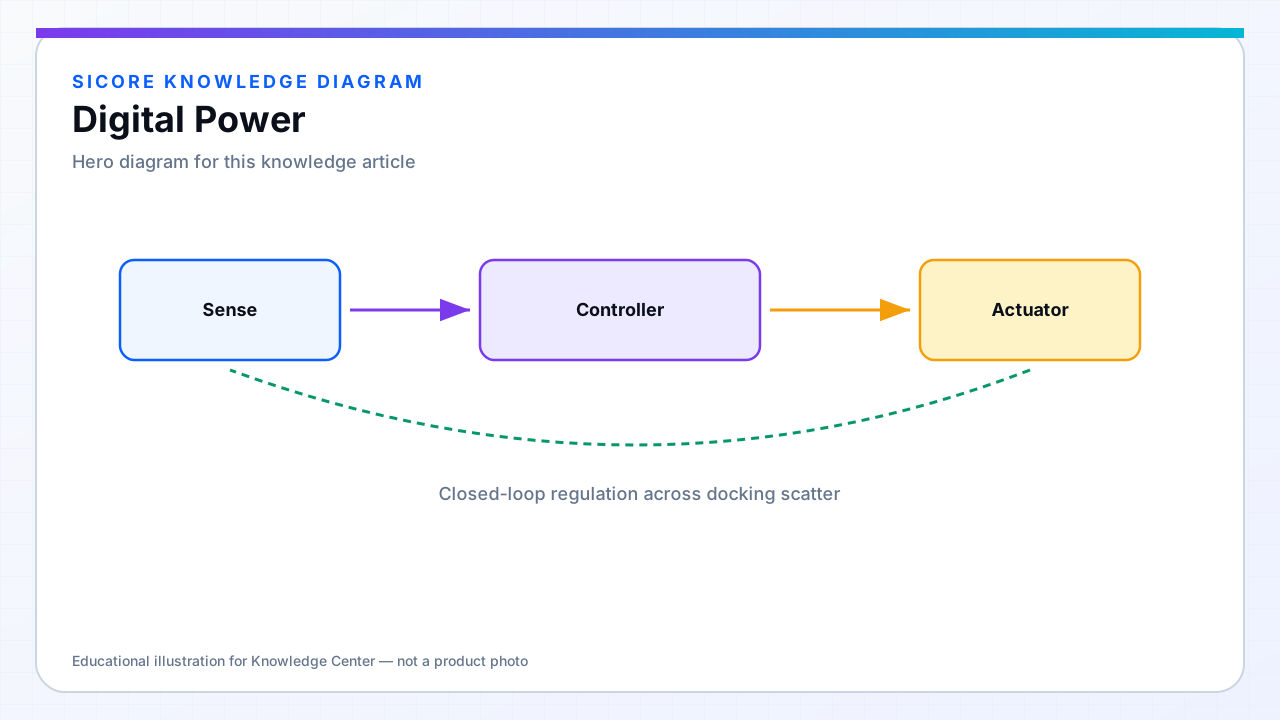
Digital power moves the resonant inverter, sensing, and protection out of fixed analog-only networks into firmware-defined loops. ADCs sample coil current, bus voltage, and temperatures at tens to hundreds of kilohertz; PWM and gate drivers execute frequency, phase, and dead-time commands computed each control period.
For AGV/AMR docks, digitization is what makes one hardware platform serve multiple power classes and coil geometries through configuration — not a respin of analog RC networks for every customer aisle width.
01Core digital blocks
- High-speed current and voltage sensing with anti-alias filtering aligned to switching harmonics.
- Resonant frequency tracker and phase modulator with explicit ZVS margin estimation.
- State machine for dock handshake, FOD pre-check, CC/CV handoff, and fault latching.
- Non-volatile parameter store for coil constants, FOD baselines, and fleet-specific derating.
02Why SiCore standardizes on digital
Digital control enables adaptive and AI layers to sit on one stack: the same firmware that enforces SOA limits also hosts optimization and telemetry. Field updates can refine control without replacing magnetics — critical when hundreds of pads are already bolted into production floors.
03Integration with the vehicle
CAN, Ethernet, or proprietary fleet buses carry setpoints, SOC targets, and diagnostics bidirectionally. The dock is a node in the robot's energy management system, not an isolated brick that blindly pushes current until something gets hot.